ROBOTICS · LEARNING · MANIPULATION

Yansong
Wu.

Learning to interact with
the physical world.

I’m a PhD candidate at the Technical University of Munich, supervised by Prof. Alois Knoll and Prof. Sami Haddadin. My research focuses on robot learning and contact-rich manipulation.

My research has evolved from robot control and model-based methods to learning-based policies. This experience has given me a broad perspective on how robots learn and act, and drives my focus on reliable contact-rich manipulation in the real world. Looking ahead, I’m excited about the future of robotics, particularly the potential of robot foundation models and embodied agents to make physical interaction more capable and adaptable.

01 / LATEST UPDATES

News.

02 / SELECTED WORK

Research highlights.

From tactile feedback
to capable robotic systems.

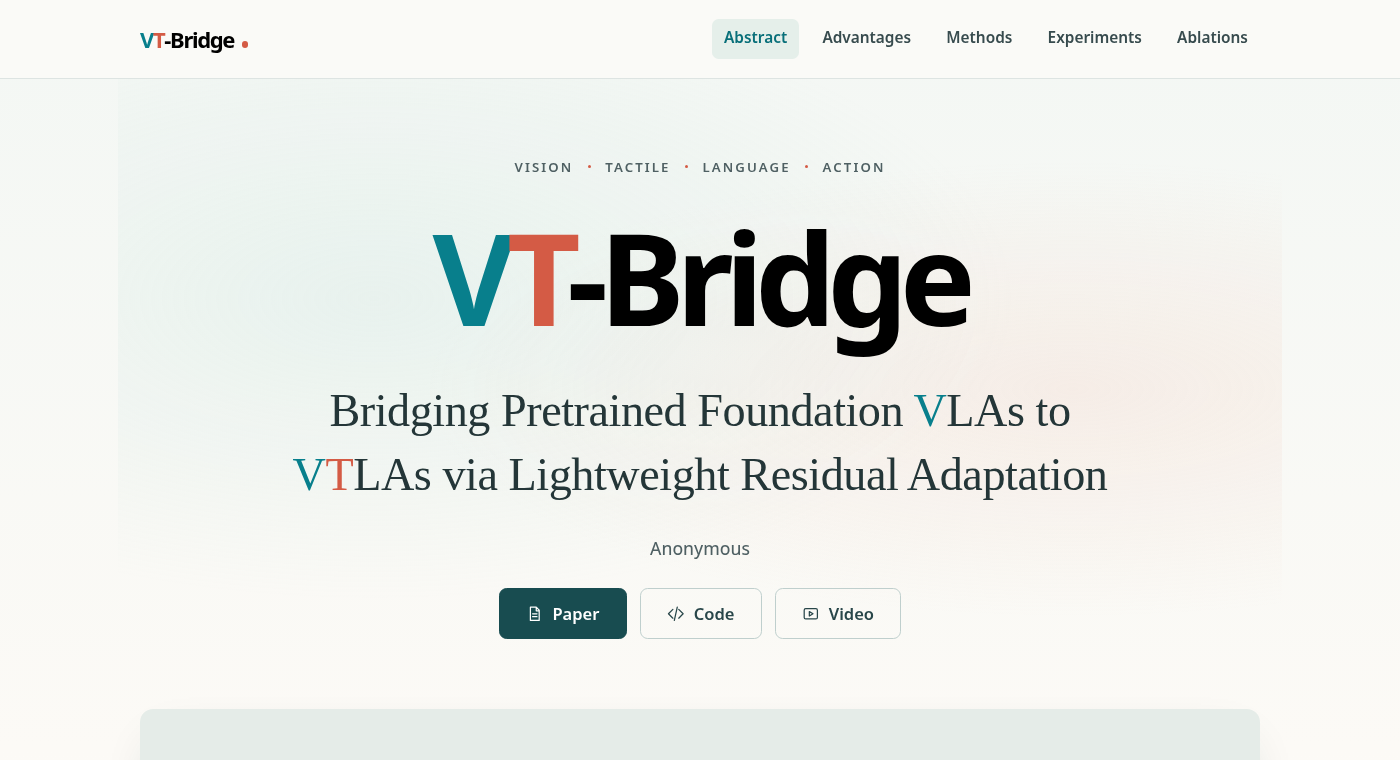
Title header of the VT-Bridge project webpage
PREPRINT · 2026Tactile robot learning

VT-Bridge

Bridging pretrained foundation VLAs to VTLAs

A lightweight residual adapter brings tactile feedback to pretrained vision-language-action models for precise contact-rich manipulation.

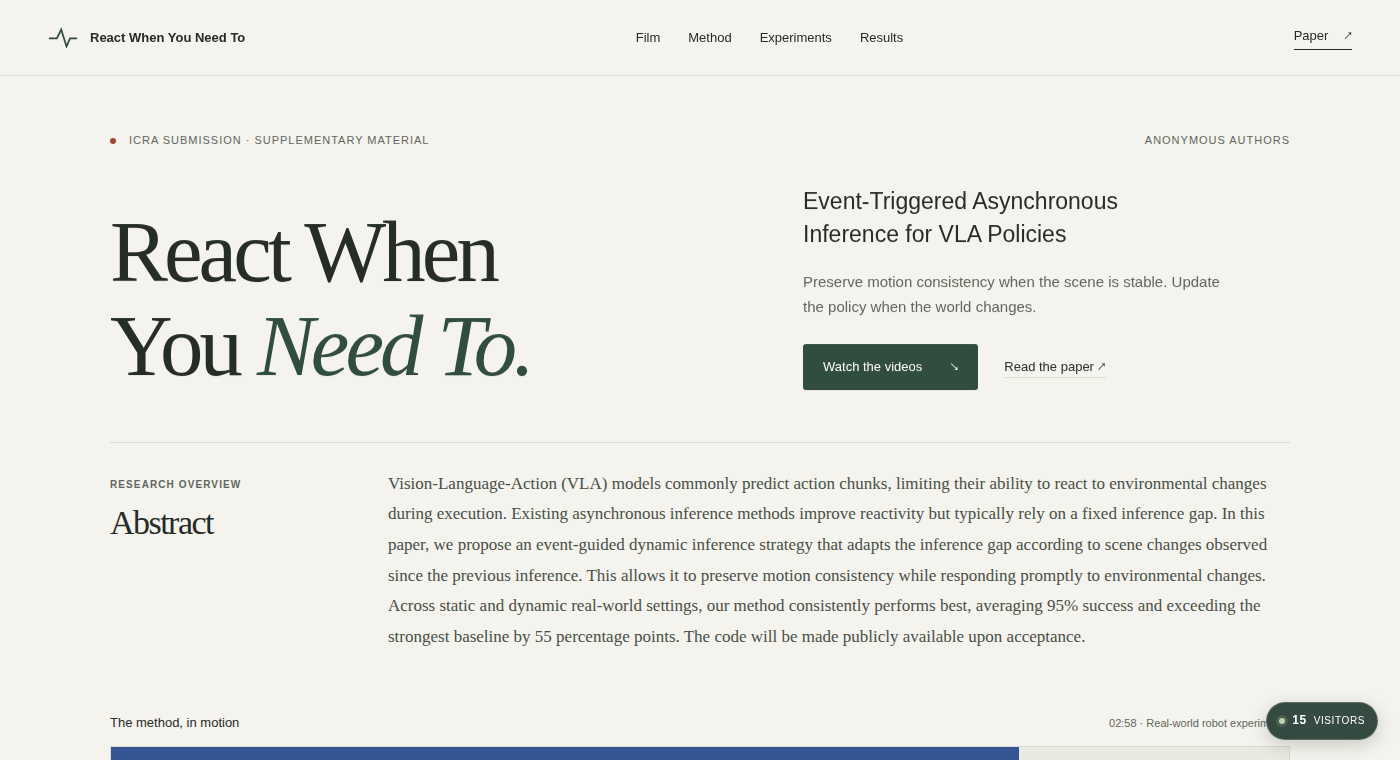
Title header of the React When You Need To project webpage
PREPRINT · 2026Vision-language-action

React When You Need To

Event-triggered asynchronous inference for VLA policies

Adapting inference timing to scene changes so robots preserve smooth motion while reacting promptly when the world changes.

03 / PUBLICATIONS

Papers & preprints.

View Google Scholar ↗

04 / LET’S CONNECT

Building the future of robotics
and physical AI.

I’m approaching the end of my PhD and exploring industry research opportunities in robot learning and manipulation. I’d be happy to discuss research, collaborations, or your team’s work.

Say hello yansong.wu@tum.de

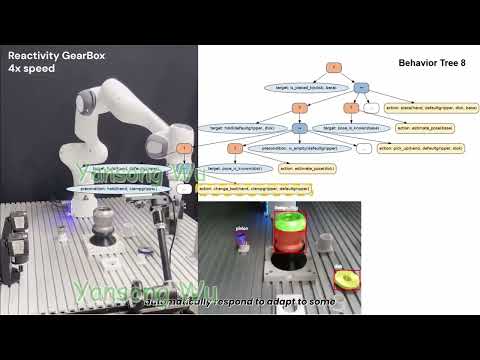
Robot demonstration

If the player is unavailable, watch on YouTube ↗.